Thomas Pan
Minor in Robotics, AI, Internet of Things
Seeking internship / co-op · US or China · Spring & Summer 2027
Builds working products from electronic hardware to embodied intelligence and finds out why when they don't.
I am an Electrical and Computer Engineer working across the stack, from embedded control and robot perception down to the silicon-level systems that make machines move wisely and safely.
Current
- Embedded Systems Hardware
- Embedded Systems Firmware
- Mechatronic Systems
- Edge-deployed AI System
- Consumer Electronics
- Mobile Robotics
Long term
Robotics · Digital IC Design · Hardware Accelerated Algorithms · Robotics SoC · Edge AI System
Selected work


Ratta “Geomcat” Automated Cat Litter Box
Ratta (Supernote) · Mechatronic Systems Engineer · Jul 2026 – Aug 2026
- Rescued a stalled project by designing all electrical, firmware, and control systems for a demo-ready inverted 4-DOF robotic arm within 6 weeks
- Product verified at Pet Fair Asia, ran nonstop for 10 hours every day during the 5-day expo.
- Built STM32 firmware, arm controller PCB schematic and layout, sim-to-real MuJoCo pipeline and control algorithm.
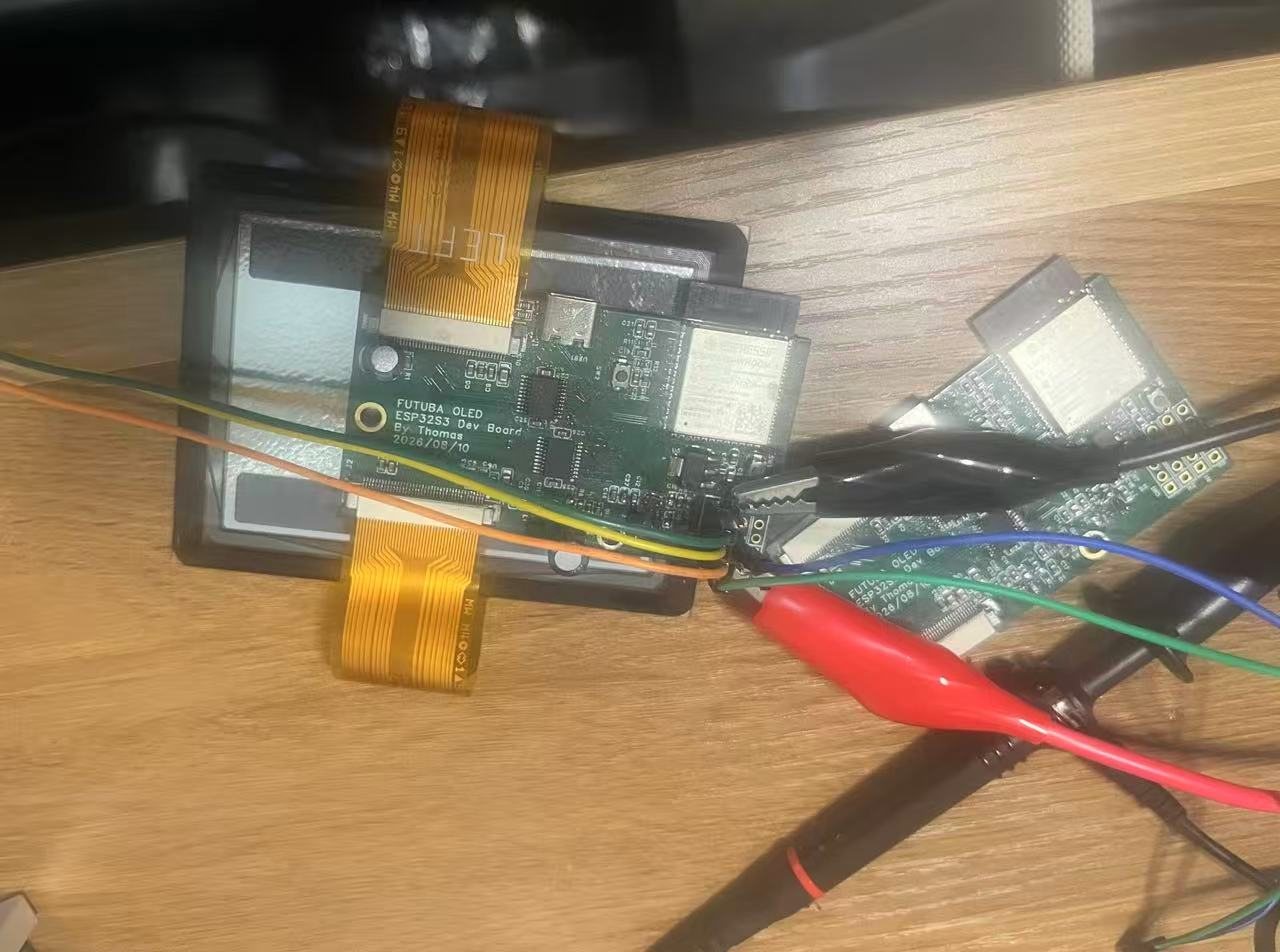
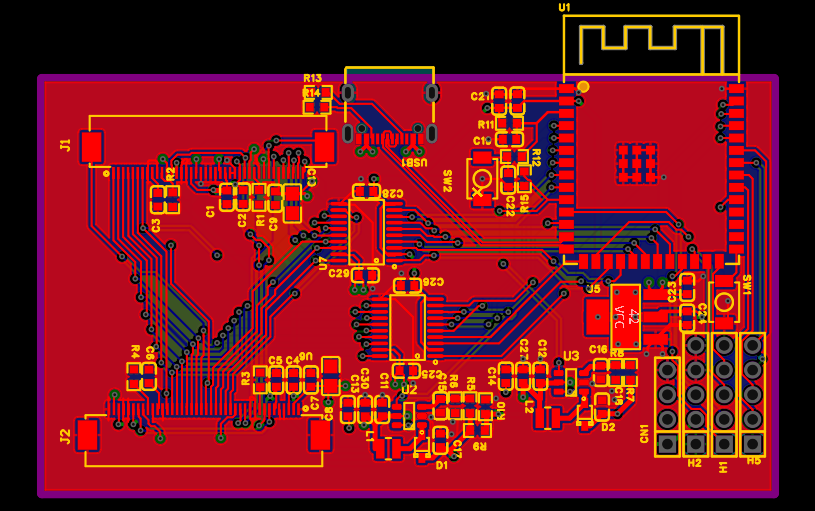
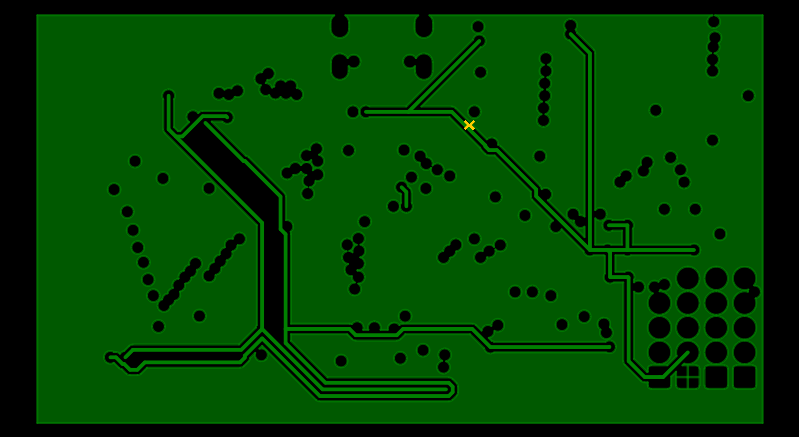
Futaba ELW3501AA OLED Driver Board
Personal hardware project · Aug 2026
- Designed and brought up a 6-layer ESP32-S3 driver board for a dual-controller 228 × 168 industrial passive-matrix OLED, achieving full-panel operation across both display halves
- Integrated 5 V level shifting and dual 16.5 V/12.9 V SX1308 boost rails, and corrected a mirrored FPC pin-mapping error in the vendor reference before fabrication
- Developed a 2 MHz ESP-IDF i80/DMA driver with dual-IC power sequencing, boost soft start, and frame-sync diagnostics that isolated power and FPC contact faults during bring-up
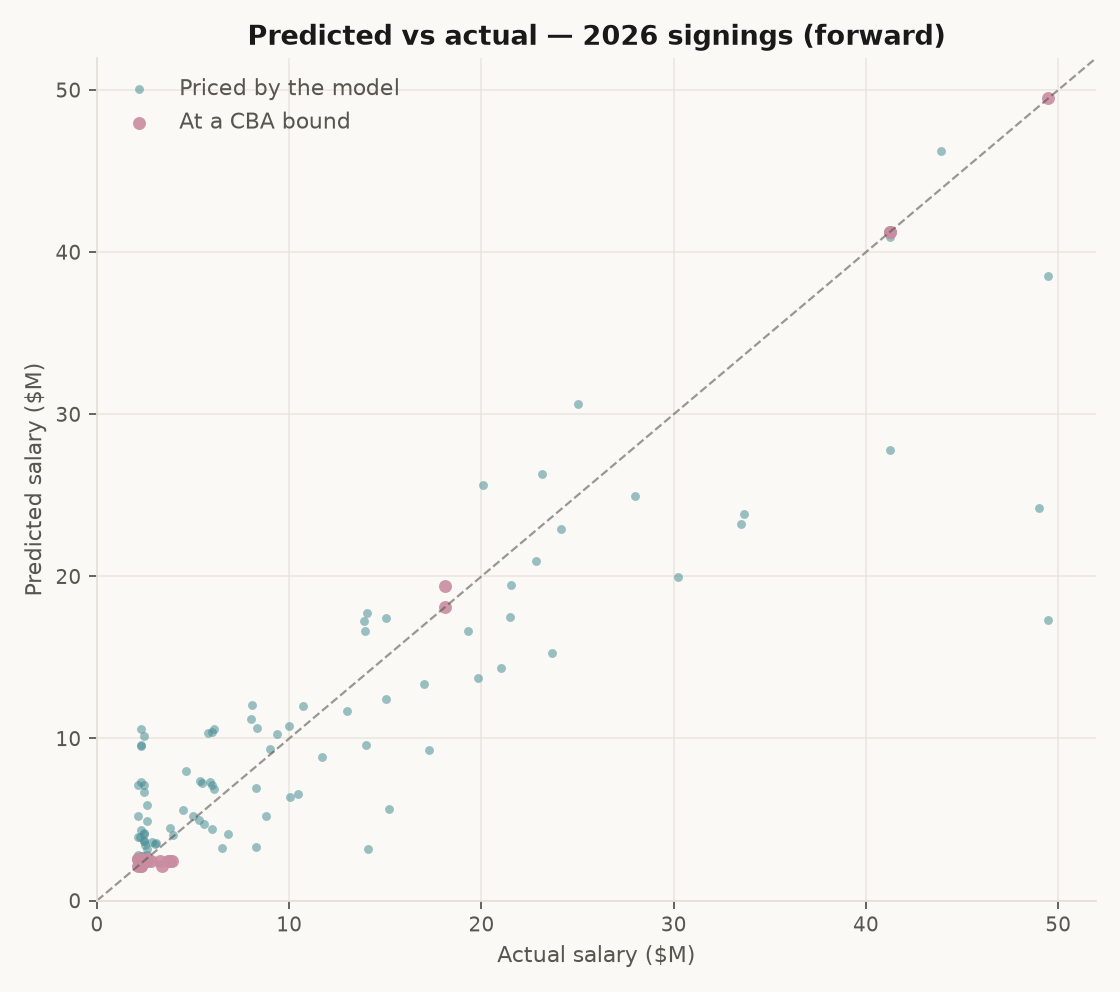
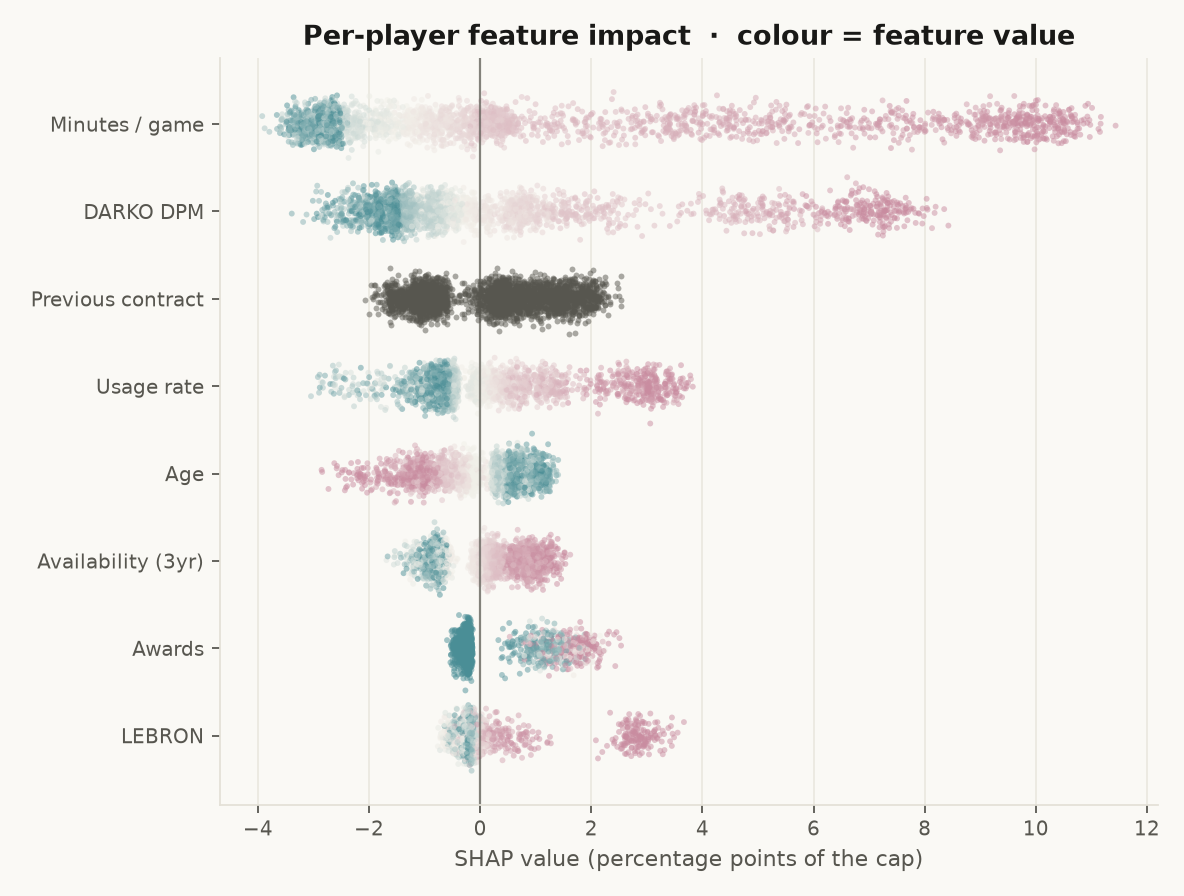
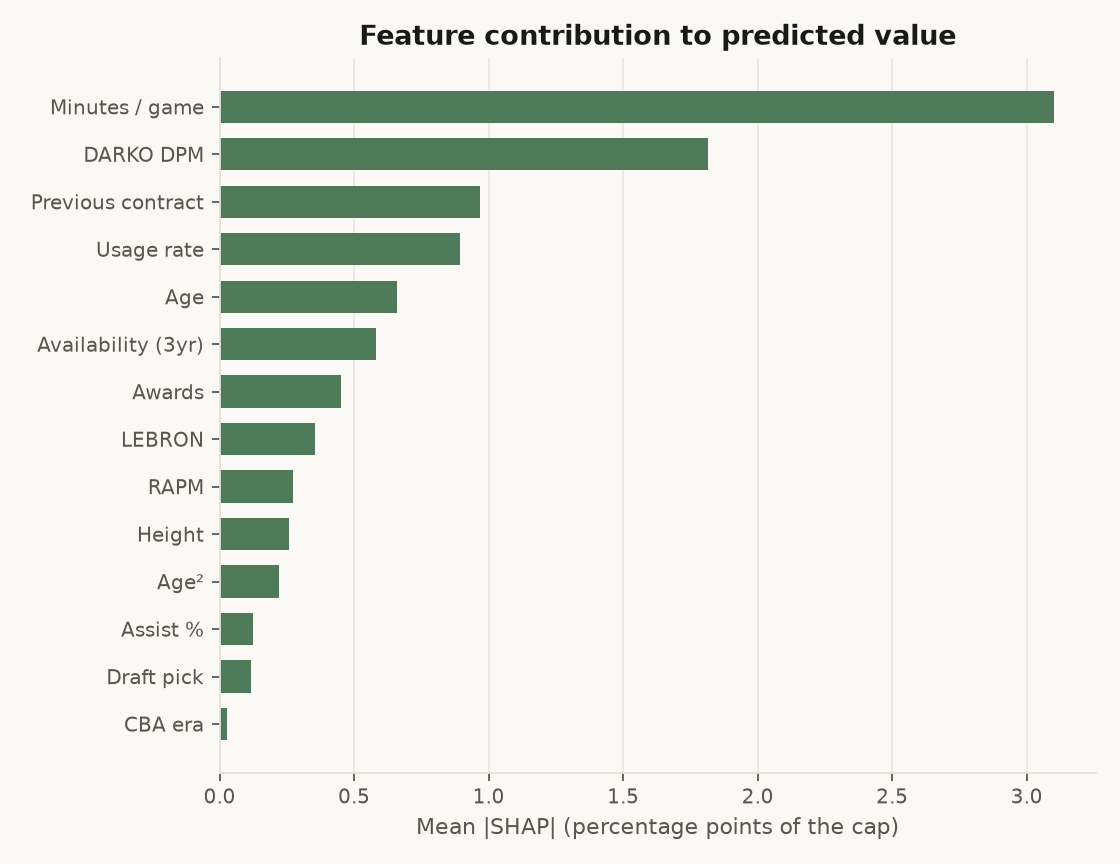
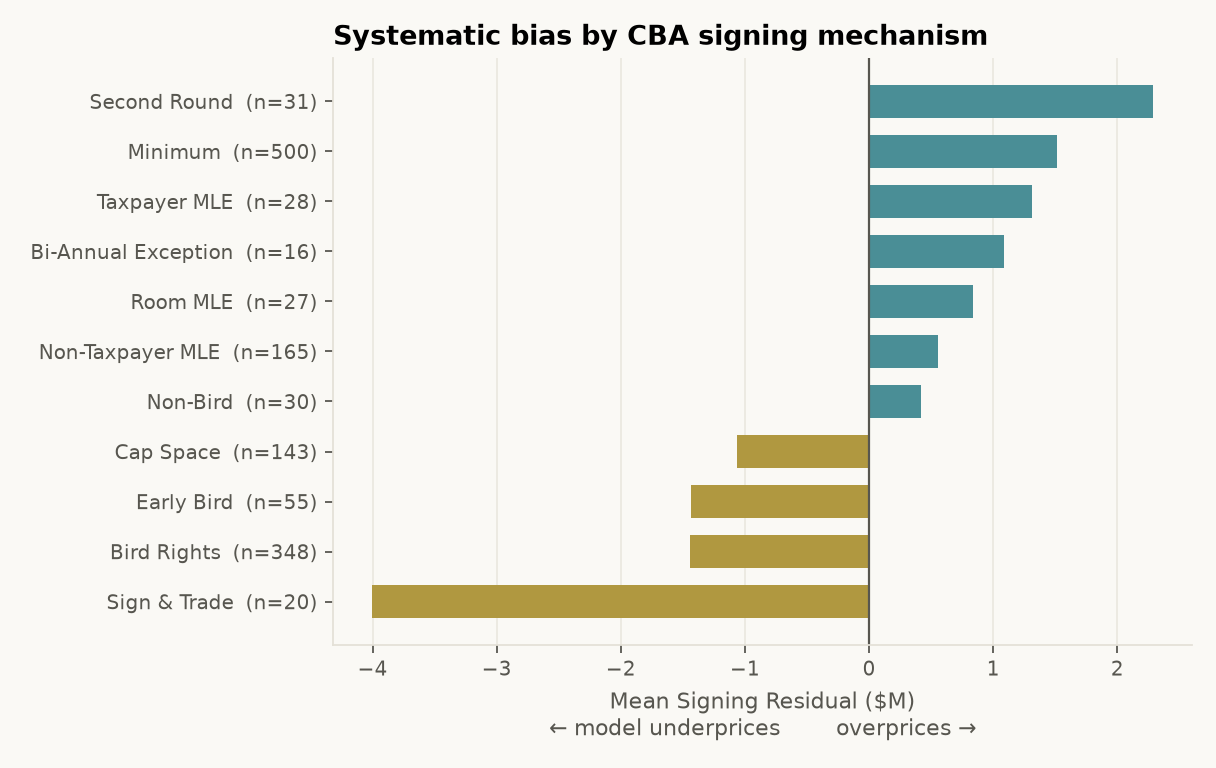
NBA Free Agent Valuation Model
Personal research project · Jun 2026 – Present
- Adapted Grabit (gradient tree-boosted Tobit) from credit-risk modeling to NBA salaries, then composed its two-sided censoring with fitted P(max) and buyout terms and a told-route extension cap so each stage answers one distinct CBA question
- Built the full pipeline end to end, scraping Basketball Reference, Spotrac and nbarapm, engineering 21 features from 40+ candidates by ablation, and a four-layer evaluation protocol that separates structural estimation from forecasting and selection from confirmation
- Established a characterized negative result: the residual pattern by signing mechanism is real but unrecoverable, with the ceiling on any fix measured empirically
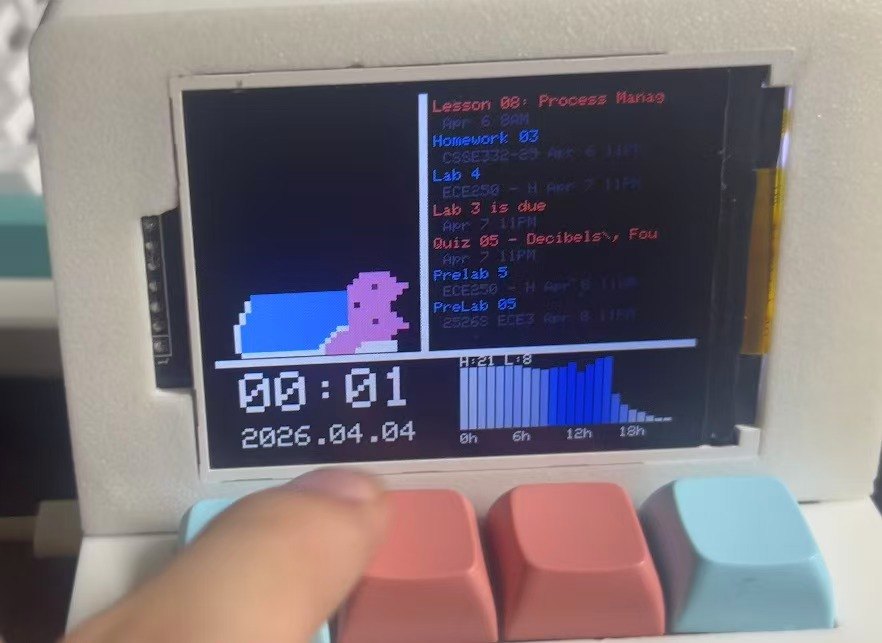
IoT Desktop Terminal
Mar 2026 – Present
- Shipped a complete embedded product. ESP32, sensors, 2.8″ SPI TFT, and 3D-printed enclosure, with FreeRTOS firmware holding 25 FPS UI alongside background networking
- Reverse-engineered PaperCut’s multi-step HTTP auth and implemented WPA2 Enterprise on ESP32 for one-button remote print release
- Implemented BLE HID wireless keyboard input and an ESP32-hosted web interface for remote configuration
MERL Robot Arm Teaching Platform
Rose-Hulman · Student Researcher, Multidisciplinary Educational Robotics Lab · Jan 2026 – Present
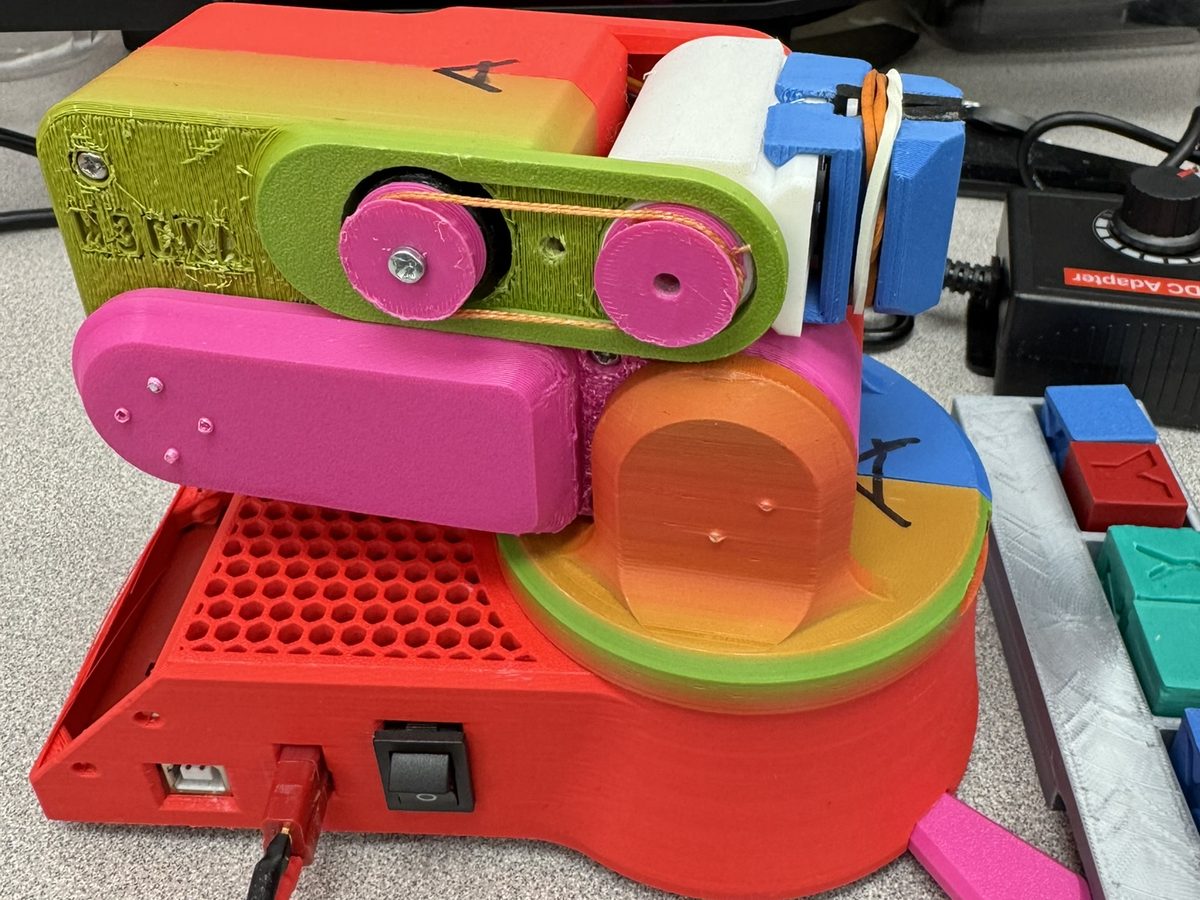
- Reworked an open-source 3D-printed 5-DOF arm into lab apparatus for a senior-level Image Processing course. Replaced the printed gear train with belts to hold tolerance at low cost, cutting the hardware failure rate from ~70% to under 5%
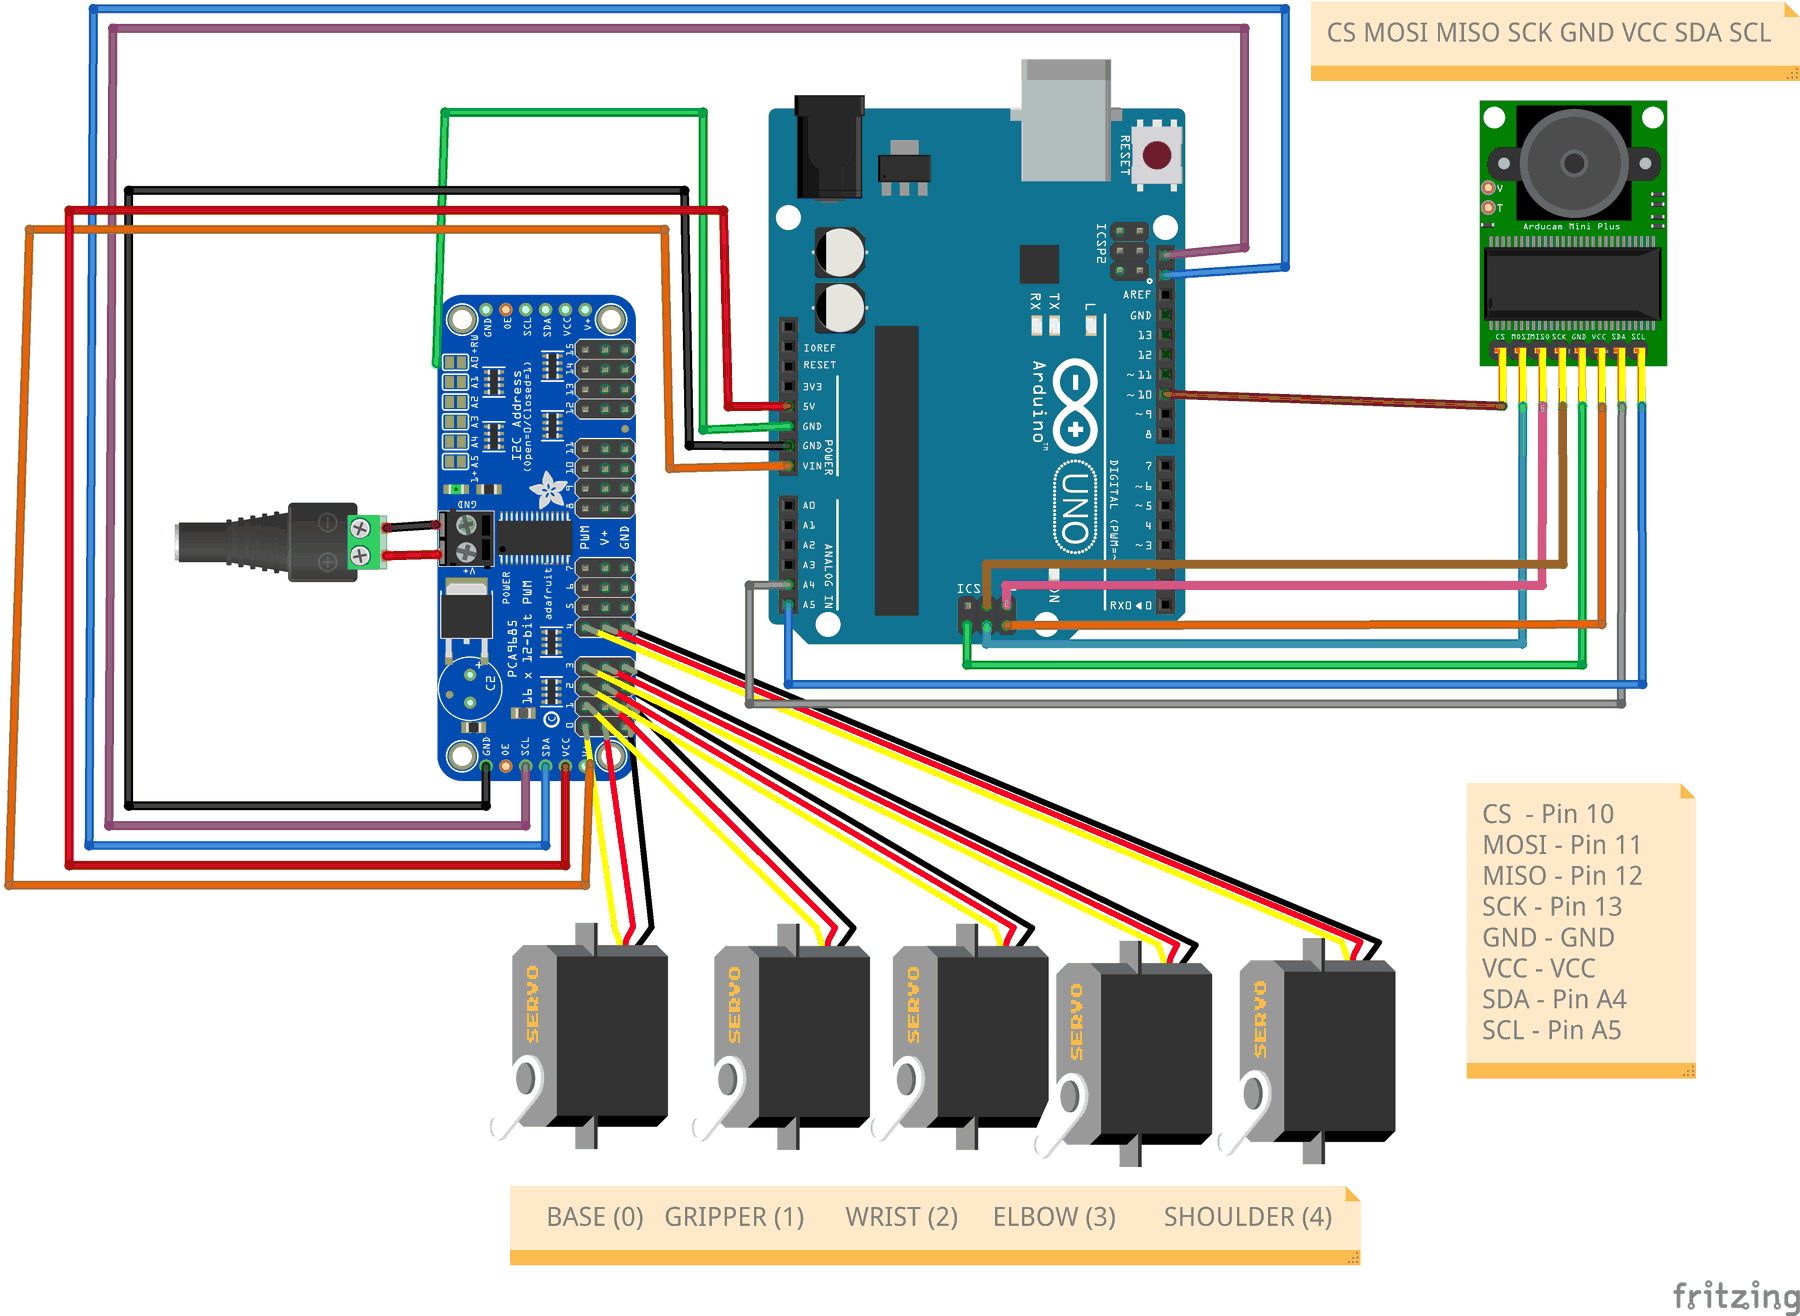
- Developed the Arduino firmware and wiring: PCA9685 servo control over I2C, per-arm pulse calibration across the lab fleet, speed-limited motion, and a serial command interface for student code
- Built a MuJoCo model of the arm from its CAD assembly and bridged it to MATLAB, so students can test a sort in simulation before running it on hardware
Summer SLAM: Visual SLAM Study Path
Rose-Hulman · Advised by Dr. Berry · Jun 2026 – Present
- Built an X-drive holonomic robot platform from scratch with an STM32F411 real-time control layer linked to a Raspberry Pi 4B ROS 2 Jazzy stack over CAN bus
- Implemented the full localization pipeline from encoder odometry through particle filter MCL (2.3 cm error) to camera calibration and ORB visual odometry
- Published each module as a reproducible tutorial with code, data logs, calibration data, and validation plots on GitHub
Current
- Embedded Systems Hardware
- Embedded Systems Firmware
- Mechatronic Systems
- Edge-deployed AI System
- Consumer Electronics
- Mobile Robotics
Long term
Robotics · Digital IC Design · Hardware Accelerated Algorithms · Robotics SoC · Edge AI System
Skill pool
- C / C++ Firmwareembedded · automotive · industrial
- ESP32 / ESP-IDFembedded · IoT
- STM32embedded · automotive
- CAN Busembedded · automotive · industrial
- OpenCVvision · machine learning
- Vision Guided Controlvision · industrial
- ROS2 NavigationSLAM · industrial
- SLAM PipelinesSLAM
- Python MLmachine learning · vision
- IoT PrototypingIoT · embedded
- Robot Motion Controlindustrial · embedded
- Automotive ECUsautomotive · embedded
- PCB Bring-upembedded · IoT
- Sensor FusionSLAM · vision · ML
- Digital Logicembedded · automotive
- Controls Modelingindustrial · embedded
No matching skills yet.